
Features
Estimate the landmark pose with respect to Robot coordinate by using offset from the origin of the landmark.
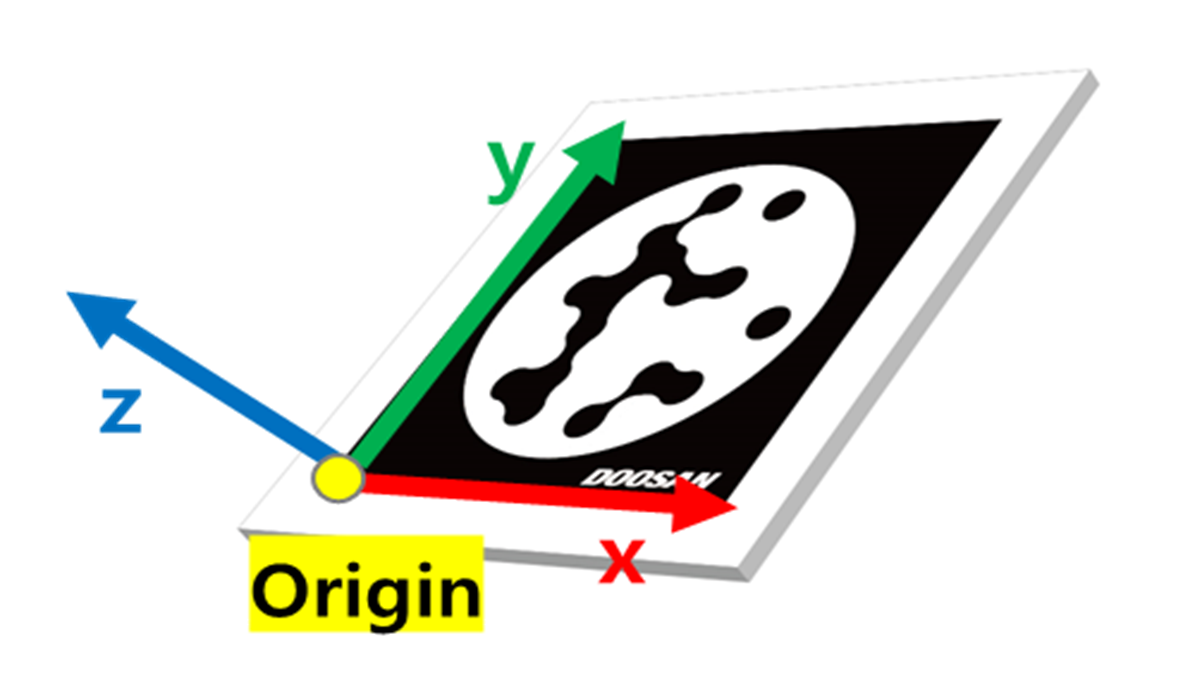
Parameters
|
Parameter Name |
Data Type |
Default Value |
Description |
|---|---|---|---|
|
cpos |
§ list[Tx, Ty, Tz, Rx, Ry, Rz] |
|
Landmark pose based on camera coordinates |
|
offset |
list[Tx, Ty, Rz] |
|
Position and angle of rotation away from the landmark origin |
|
euler_mode |
boolean |
|
Orientation option for Landmark pose with respect to Robot coordinate: ZYZ for “True”, XYZ for “False” |
Return
|
Value |
Data Type |
Description |
|---|---|---|
|
rpos |
list[Tx, Ty, Tz, Rz, Ry, Rz'] or list[Tx, Ty, Tz, Rx, Ry, Rz] |
Landmark pose based on robot coordinates or Landmark pose with offset set |
|
-1 |
Int |
Fail – no measurement data or input variable error |
Example
Python
svm_connect()                             # Connect to vision

offset = [10,-20, 45]
euler_mode = True
rpos = svm_get_marker_offset_pose(cpos, offset, euler_mode)
tp_popup("Landmark with respect to Robot={0}".format(rpos))
svm_disconnect()                            # Disconnect to vision